Canonical HTML: https://autolyap.github.io/examples/nesterov_momentum/smooth_convex/
Documentation version: 0.2.1
# The gradient method with constant Nesterov momentum: Smooth and convex
## Problem setup
Consider the unconstrained minimization problem
\[\minimize_{x \in \calH} f(x) \quad \iff \quad \text{find } x \in \calH \;\text{ such that }\; 0 \in \partial f(x) = \set{\nabla f(x)},\]
where \(f : \calH \to \reals\) is convex and \(L\)-smooth with
\(L>0\).
For initial points \(x^{-1}, x^0 \in \calH\), momentum
\(\delta \in \reals\), and step size \(\gamma \in \reals_{++}\), the gradient method with constant Nesterov momentum is
\[\begin{split}(\forall k \in \naturals)\quad
\left[
\begin{aligned}
y^k &= x^k + \delta(x^k - x^{k-1}), \\
x^{k+1} &= y^k - \gamma \nabla f(y^k).
\end{aligned}
\right.\end{split}\]
In this example, we search for a feasible Lyapunov certificate with
\(\rho=1\) and condition (C4) enabled such that
\[f(y^k) - f(y^\star) \in o\!\left(\frac{1}{k}\right) \quad \textup{ as } \quad k\to\infty,\]
where \(y^\star \in \Argmin_{x \in \calH} f(x)\).
## Model the problem in AutoLyap and certify sublinear convergence
- \(f\) is modeled by
[`SmoothConvex`](https://autolyap.github.io/function_classes/#autolyap.problemclass.SmoothConvex "autolyap.problemclass.SmoothConvex").
- The optimization problem is represented by
[`InclusionProblem`](https://autolyap.github.io/problem_class/#autolyap.problemclass.InclusionProblem "autolyap.problemclass.InclusionProblem").
- The update rule is represented by
[`GradientNesterovMomentum`](https://autolyap.github.io/concrete_algorithms/#autolyap.algorithms.GradientNesterovMomentum "autolyap.algorithms.GradientNesterovMomentum").
- Sublinear function-value parameters are obtained with
[`IterationIndependent.SublinearConvergence.get_parameters_function_value_suboptimality`](https://autolyap.github.io/iteration_independent_analysis/#autolyap.IterationIndependent.SublinearConvergence.get_parameters_function_value_suboptimality "autolyap.IterationIndependent.SublinearConvergence.get_parameters_function_value_suboptimality").
- Feasibility at fixed \(\rho=1\) is checked with
[`IterationIndependent.search_lyapunov`](https://autolyap.github.io/iteration_independent_analysis/#autolyap.IterationIndependent.search_lyapunov "autolyap.IterationIndependent.search_lyapunov") and `remove_C4=False`.
## Run the iteration-independent analysis
This example uses the MOSEK Fusion backend (`backend="mosek_fusion"`).
Install the optional MOSEK dependency first:
```bash
pip install "autolyap[mosek]"
```
```python
from autolyap import IterationIndependent, SolverOptions
from autolyap.algorithms import GradientNesterovMomentum
from autolyap.problemclass import InclusionProblem, SmoothConvex
L = 1.0
gamma = 1.0
delta = 0.5
problem = InclusionProblem([SmoothConvex(L)])
algorithm = GradientNesterovMomentum(gamma=gamma, delta=delta)
MOSEK_PARAMS = {
"intpntCoTolPfeas": 1e-6,
"intpntCoTolDfeas": 1e-6,
"intpntCoTolRelGap": 1e-6,
"intpntMaxIterations": 10000,
}
solver_options = SolverOptions(
backend="mosek_fusion",
mosek_params=MOSEK_PARAMS,
)
# License-free option:
# solver_options = SolverOptions(backend="cvxpy", cvxpy_solver="CLARABEL")
# Build V(P, p, k) and R(T, t, k) for function-value suboptimality.
P, p, T, t = IterationIndependent.SublinearConvergence.get_parameters_function_value_suboptimality(
algorithm,
tau=0,
)
result = IterationIndependent.search_lyapunov(
problem,
algorithm,
P,
T,
p=p,
t=t,
rho=1.0,
remove_C4=False,
solver_options=solver_options,
)
if result["status"] != "feasible":
raise RuntimeError("No feasible Lyapunov certificate for this (gamma, delta) pair.")
print("Feasible certificate found with C4 enabled.")
```
What to inspect in `result`:
- `result["status"]`: `feasible`, `infeasible`, or `not_solved`.
- `result["solve_status"]`: raw backend status.
- `result["rho"]`: the fixed contraction parameter (`1.0` in this sublinear setup).
- `result["certificate"]`: Lyapunov certificate matrices/scalars.
When the certificate is feasible, the certified function-value convergence is
\[f(y^k) - f(y^\star) \in o\!\left(\frac{1}{k}\right)
\quad \textup{ as } \quad k\to\infty,\]
where \(y^\star \in \Argmin_{x \in \calH} f(x)\).
Equivalently,
\[\lim_{k \to \infty} k\bigl(f(y^k)-f(y^\star)\bigr)=0.\]
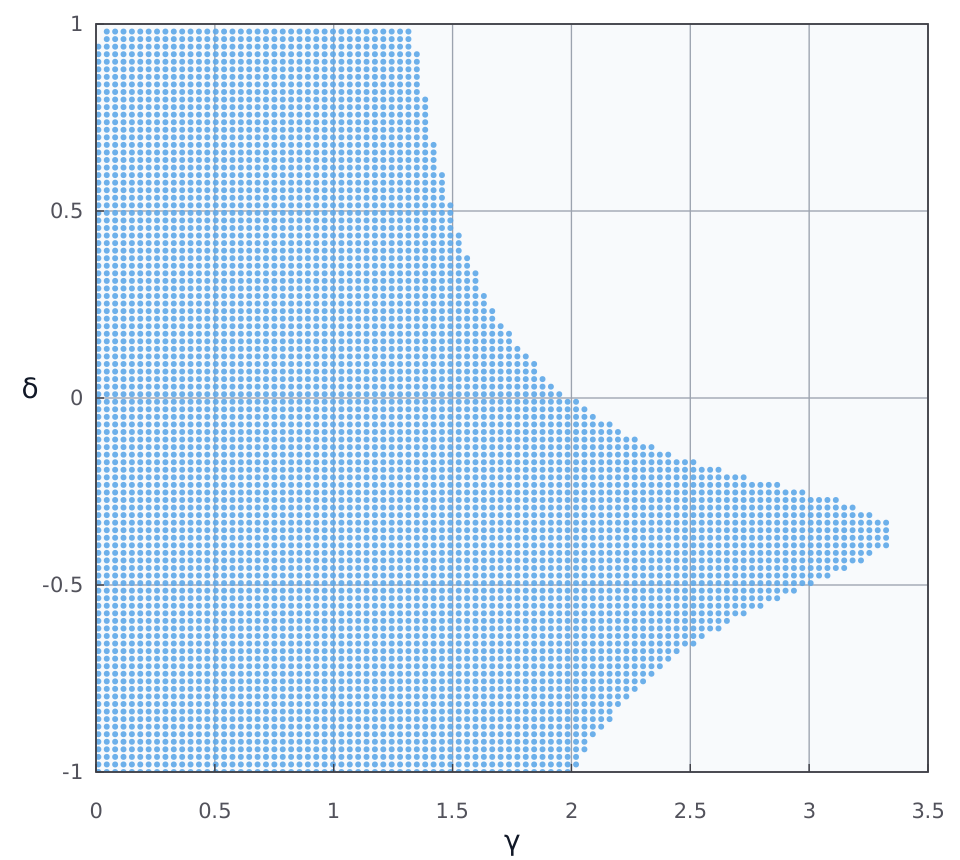
Sweeping over multiple values of \(\gamma \in (0,4)\) and
\(\delta \in (-1,1)\) with \(L=1\) gives the plot below, where each
blue dot denotes a parameter pair with a feasible certificate.
[](https://autolyap.github.io/_images/nesterov_momentum_smooth_convex.svg)
## References
TeX macro definitions used in this page:
```latex
\newcommand{\Argmin}{\operatorname*{Argmin}}
\newcommand{\calH}{\mathcal{H}}
\newcommand{\minimize}{\operatorname*{minimize}}
\newcommand{\naturals}{\mathbb{N}_{0}}
\newcommand{\reals}{\mathbb{R}}
\newcommand{\set}[1]{\mathord{\left.\{ #1 \} \right. }}
```